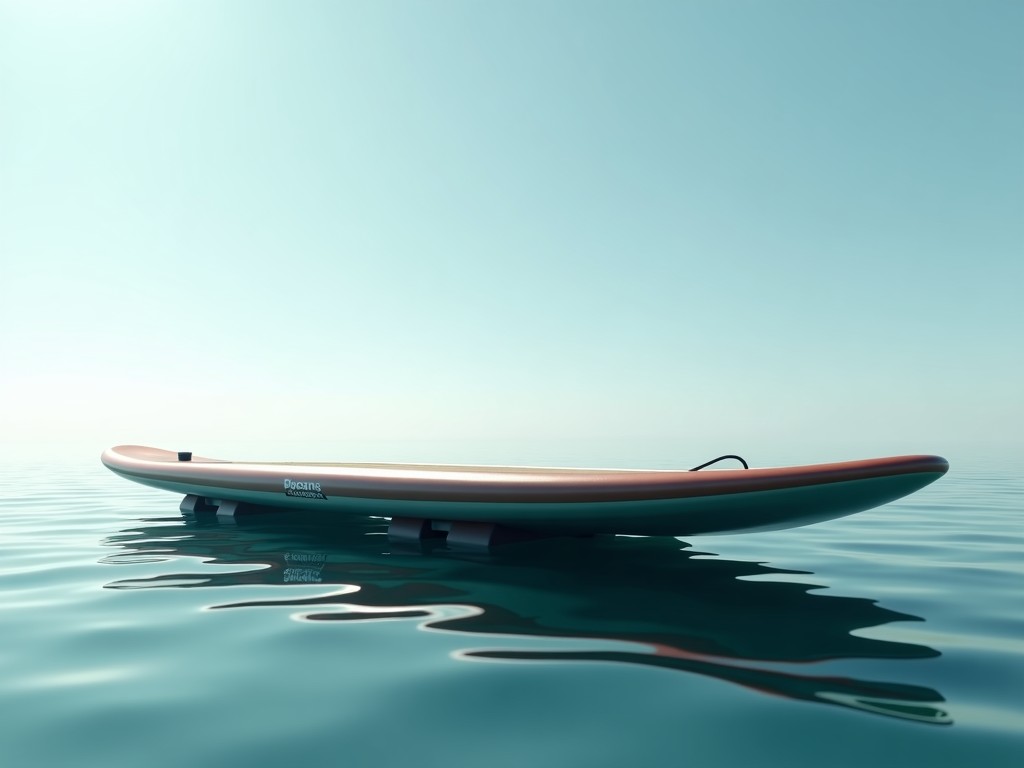
Rechargeable Self Powered Hydrofoil Surfboard
Rechargeable Self-Powered Hydrofoil Surfboard
A rechargeable self-powered hydrofoil surfboard integrates electric propulsion with hydrofoil lift technology to enable sustained waterborne operation without waves or wind. The system combines a sealed lithium-ion battery pack, waterproof electric motor, and aerodynamically optimized foil assembly to generate thrust and lift independently of environmental conditions. This configuration allows riders to achieve planing speeds on flat water while minimizing drag through airborne foil support.
Core System Architecture
The propulsion unit consists of a brushless DC motor rated for continuous operation at 5–7 kW, housed in a marine-grade aluminum casing with IP68 sealing. Power is delivered via a sensorless electronic speed controller (ESC) that manages current flow based on throttle input and motor temperature feedback. The battery system uses 21700-format lithium-ion cells arranged in a 14S4P configuration, delivering 51.8 V nominal voltage and 20 Ah capacity, encased in a flame-retardant, impact-resistant polymer shell with integrated thermal management.
Hydrodynamic lift is generated by a front foil and rear stabilizer constructed from carbon fiber-reinforced polymer with a NACA 0012 profile. The front foil spans 900 mm with a root chord of 180 mm, designed to produce lift at speeds as low as 8 km/h. The rear stabilizer measures 600 mm in span with a symmetric profile to maintain pitch stability. Connection points between mast, fuselage, and wings use aerospace-grade titanium fasteners with torque specifications calibrated to prevent galvanic corrosion in saltwater environments.
Performance Characteristics
Under standard test conditions (22°C ambient, calm water, 75 kg rider), the system achieves a maximum speed of 35 km/h with a sustained cruising range of 25 km at 20 km/h. Acceleration from 0 to 20 km/h occurs in 4.2 seconds under full throttle. Energy consumption averages 180 Wh/km at cruising speed, with regenerative braking capable of recovering up to 8% of kinetic energy during deceleration. The total system weight, including battery and foil assembly, is 29 kg.
| Parameter | Value | Condition |
|---|---|---|
| Max Speed | 35 km/h | Full throttle, 75 kg rider |
| Cruising Range | 25 km | 20 km/h constant speed |
| Charge Time | 120 min | 1C charging, 25°C |
| Operating Temp | -10°C to 45°C | Battery discharge limits |
| Depth Rating | 1.5 m | Continuous submersion |
Materials and Construction
The board’s core is a closed-cell polystyrene foam blank reinforced with unidirectional carbon fiber laminates along the longitudinal axis, providing a flexural modulus of 4.2 GPa and impact resistance exceeding 15 kJ/m². The deck surface features a diamond-pattern EVA foam overlay with 5 mm thickness and Shore A 60 hardness for grip and UV stability. All external fasteners are grade 5 titanium, and sealing interfaces use dual-lip nitrile rubber gaskets with PTFE coating to resist saltwater degradation over 500+ hours of exposure.
The mast is fabricated from 6061-T6 aluminum extrusion with anodized finish (25 μm thickness), designed to withstand 12 kN bending moments at the fuselage junction. Internal cable routing follows a sealed conduit system with strain relief at entry points to prevent abrasion-induced failure. The motor mounting interface incorporates a vibration-damping polymer isolator rated for 10–500 Hz frequencies to reduce transmission of mechanical noise to the rider’s stance.
Operational and Safety Features
The system includes a magnetic safety lanyard that cuts motor power within 120 ms of detachment, meeting ISO 13849-1 PLr safety function requirements. Battery management monitors cell voltage, temperature, and current imbalance, triggering shutdown if any cell exceeds 4.25 V or drops below 2.8 V, or if temperature exceeds 60°C. A handlebar-mounted throttle uses Hall-effect sensors with redundant signal paths and returns to idle position via spring tension if displaced beyond 15° from neutral.
Diagnostic indicators consist of a waterproof LED array displaying battery state of charge in 20% increments, fault codes via flashing patterns, and system readiness status. Wireless telemetry via Bluetooth 5.0 transmits real-time data (speed, voltage, motor temperature) to a companion app for logging and performance analysis. Charging is conducted through a magnetic DC connector with automatic polarity correction and overvoltage protection clamped at 58.8 V.
Applications and Use Cases
This technology enables consistent training environments for hydrofoil athletes in inland lakes, reservoirs, and calm coastal zones where wave-dependent foiling is impractical. Commercial operators use these systems for guided tours in protected marine areas, eliminating noise and emissions associated with fuel-powered alternatives. Rescue and patrol units benefit from silent operation and rapid deployment in shallow water scenarios where traditional vessels cannot navigate. The self-contained power source also supports scientific instrumentation deployment for nearshore environmental monitoring.
In educational settings, the predictable thrust and lift characteristics allow students to isolate hydrofoil control variables without environmental interference. Military reconnaissance teams utilize the low acoustic signature for littoral zone observation. The modular design permits interchangeable foil sets for speed optimization (high-aspect ratio) or stability training (low-aspect ratio, increased surface area), supporting progressive skill development across user groups.
Customization and Integration Options
Battery capacity can be scaled between 16 Ah and 28 Ah by adjusting cell parallelism, affecting range and weight proportionally. Motor windings are available in Kv ratings from 180 to 300 RPM/V to match propeller pitch and desired speed-torque curves. Foil geometries can be customized for specific water conditions—high-lift, low-speed foils for freshwater (Reynolds number < 500,000) and high-speed, cavitation-resistant profiles for saltwater operation.
Deck dimensions (length, width, thickness) can be adjusted within ±15% of baseline to accommodate rider height, weight, and stance preferences. Control interfaces support CAN bus expansion for auxiliary systems such as GPS navigation, sonar depth sensing, or payload release mechanisms. All customizations undergo finite element analysis and hydrodynamic simulation to validate structural integrity and performance targets prior to tooling.
Quality Control and Testing
Each unit undergoes hydrostatic pressure testing at 2.5 bar for 10 minutes to validate sealing integrity. Battery packs are subjected to vibration profiles simulating 50 hours of ocean chop (10–100 Hz, 0.5 G RMS) followed by thermal cycling between -20°C and 55°C. Motor insulation resistance is measured at 500 V DC with a minimum threshold of 100 MΩ. Final assembly includes a 30-minute operational test cycle at varying speeds and steering angles to verify ESC throttle response and fault detection.
Hydrofoil alignment is verified using laser tracking systems with tolerance of ±0.5° in angle of attack and ±2 mm in longitudinal position. Surface finish of carbon fiber components is assessed via profilometry to ensure roughness average (Ra) < 3.2 μm for minimized drag. Documentation includes material traceability logs, test certificates, and a unique serial number linking to production batch records. Sampling plans follow ISO 2859-1 for lot acceptance based on critical functional parameters.