High Speed Electric Jet Board
High Speed Electric Jet Board
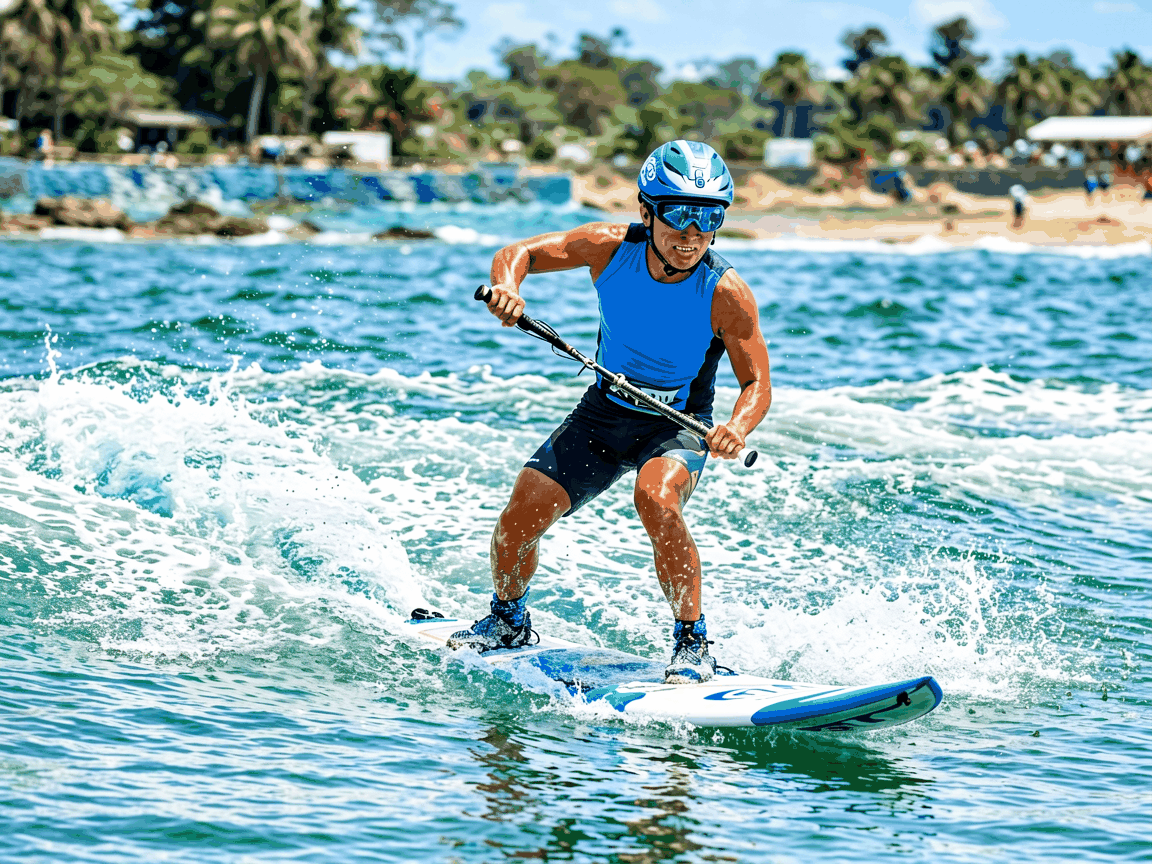
Electric jet boards represent a propulsion technology where water is drawn into an enclosed impeller system and expelled at high velocity to generate thrust, enabling planing or semi-planing operation on water surfaces without external tow or sails. Unlike propeller-driven systems, jet propulsion eliminates exposed rotating blades, reducing entanglement risk with debris, vegetation, or submerged structures—a critical advantage in shallow, vegetated, or confined waterways. The absence of a propeller also allows operation in water depths as low as 10–15 cm, depending on intake design, expanding usability in tidal flats, marsh edges, and rocky shorelines where conventional drives would ground or sustain damage. Electric jet boards integrate this principle with battery-electric power delivery, removing internal combustion emissions, noise, and fuel logistics while maintaining instantaneous torque response. For industrial users, this translates to reduced operational complexity in sensitive environments such as wildlife reserves, aquaculture zones, or inland waterways with strict emissions regulations.
Performance is governed by the relationship between electrical power input, impeller efficiency, nozzle velocity, and hull hydrodynamics. Thrust (F) can be approximated by F = ṁ × (v_j - v_0), where ṁ is mass flow rate of water, v_j is jet exit velocity, and v_0 is inflow velocity—highlighting that maximizing exit velocity relative to inflow is key to efficiency. High-speed operation requires minimizing hull wetted surface area and optimizing planing attitude to reduce drag, which increases quadratically with speed. Battery energy density directly impacts runtime; current lithium-ion systems typically deliver 150–250 Wh/kg, meaning a 5 kWh pack weighing ~25 kg might sustain 20–30 minutes of high-speed operation (>35 km/h) depending on duty cycle and water conditions. Thermal management of both motor and battery packs becomes critical under sustained load, as efficiency losses manifest as heat that must be dissipated to prevent performance throttling or cell degradation.
Core Technical Specifications
| Parameter | Typical Range | Notes |
|---|---|---|
| Peak Power Output | 5–15 kW | Determines acceleration and top speed; limited by battery discharge rate and motor thermal limits. |
| Top Speed | 35–55 km/h | Achievable under optimal conditions; actual speed varies with rider weight, water salinity, and wave state. |
| Continuous Power | 3–8 kW | Sustained output before thermal derating; critical for patrol or survey missions requiring extended runtime. |
| Battery Capacity | 3–8 kWh | Lithium-ion NMC or LFP chemistries; influences runtime and recharge time. |
| Charge Time (80%) | 1–3 hours | Depends on charger power (AC/DC) and battery management system; fast charging may reduce cycle life. |
| Operating Temperature Range | -10°C to 45°C | Limited by battery chemistry; performance decreases outside this range due to ionic conductivity and internal resistance changes. |
| IP Rating (Electronics) | IP67/IP68 | Ensures dust tightness and protection against temporary or continuous immersion; vital for marine environments. |
| Hull Material | Carbon fiber, fiberglass, or marine-grade aluminum | Affects weight, stiffness, corrosion resistance, and repair feasibility; carbon fiber offers highest strength-to-weight but requires specialized repair. |
Propulsion System Design
The jet pump consists of an inlet grate, impeller, stator vanes, and acceleration nozzle. The inlet grate prevents large debris (>10–15 mm) from entering the pump chamber, protecting the impeller from damage—a common failure mode in sandy or vegetated waters. Impeller design balances flow rate and pressure rise; axial-flow impellers are typical for high-speed applications due to their ability to handle large flow volumes with moderate pressure heads. Stator vanes downstream of the impeller straighten the rotational flow, converting angular momentum into axial thrust and improving efficiency by 10–15% compared to rudderless designs. The acceleration nozzle, often made of UV-stabilized polymer or composite, shapes the jet stream; a convergent nozzle increases exit velocity but risks flow separation if over-constrained, while a poorly designed nozzle can cause cavitation at high power levels, eroding metal surfaces and reducing efficiency.
Motor selection is typically a permanent magnet synchronous motor (PMSM) due to its high power density (>4 kW/kg), wide constant-power speed range, and precise torque control via field-oriented control (FOC). Motor cooling is achieved through direct water jackets or indirect conduction via the hull; water-cooled stators maintain winding temperatures below 120°C under continuous load, preventing insulation degradation. The electronic speed controller (ESC) manages power delivery from battery to motor, incorporating regenerative braking during deceleration to recover 5–15% of kinetic energy back into the battery, extending effective range in stop-and-go operational profiles. Sensors monitor motor temperature, battery state-of-charge (SoC), and impeller RPM, feeding data to a microcontroller that enforces safety limits—such as motor cutoff at 90°C or battery discharge below 20% SoC—to prevent damage.
Battery and Energy System
Battery packs are modular, sealed units designed for marine ingress protection, typically using prismatic or pouch lithium-ion cells arranged in series-parallel configurations to meet voltage (usually 48–72 V nominal) and capacity requirements. Cell balancing is managed by a battery management system (BMS) that monitors individual cell voltages, temperatures, and currents, triggering shutdown if any cell exceeds 4.25 V or drops below 2.5 V, or if temperature surpasses 60°C. Thermal runaway prevention includes inter-cell barriers, pressure-release vents, and externally mounted fuses rated for DC fault currents. Pack enclosures are often aluminum or reinforced polymer with conformal coating on PCBs to resist salt fog corrosion, validated via ASTM B117 salt spray testing for 500+ hours.
Energy density determines the trade-off between runtime and portability; LFP chemistries offer longer cycle life (2000+ cycles) and better thermal stability but lower specific energy (~90–120 Wh/kg) compared to NMC (~150–220 Wh/kg). For industrial applications requiring daily cycling, LFP may reduce total cost of ownership despite higher initial weight. Charging is conducted via conductive connectors (e.g., M12 or circular military-style) or inductive systems; conductive plugs feature gold-plated contacts and mechanical keys to prevent misalignment, with IP68 ratings when mated. Some systems support DC fast charging up to 10 kW, though this requires active cooling during charge to mitigate lithium plating risks at low temperatures or high states of charge.
Hull Hydrodynamics and Materials
Hull shape directly influences planing efficiency, stability, and spray characteristics. A deep-V hull (20–24° deadrise) provides better wave penetration and softer ride in chop but increases wetted surface and drag at speed, reducing top speed by 5–8 km/h compared to a flat-bottom design. Flat or modified V hulls plane earlier and achieve higher top speeds but transmit more impact load to the rider in rough water, increasing fatigue during prolonged use. Sponsons or chines along the hull sides improve lateral stability and reduce porpoising—a cyclic pitch oscillation that occurs when the center of pressure shifts aft relative to the center of gravity at high speed. Water intake is typically located forward of the center of gravity to minimize trim change during acceleration, as a forward inlet reduces bow-down trim caused by jet reaction force.
Material choice affects not only weight but also repairability and lifecycle cost. Carbon fiber hulls offer tensile strength >3.5 GPa and density ~1.6 g/cm³, enabling thinner laminates and lower displacement, but require vacuum bagging or autoclave curing for optimal fiber wet-out and void reduction (<2%). Repair involves scarfing damaged layers and re-laminating with epoxy resin, a process requiring controlled temperature and humidity. Fiberglass is more forgiving (tensile strength ~1.0–1.4 GPa, density ~1.8–2.0 g/cm³), easier to repair with hand lay-up, and less expensive, though it absorbs more water over time if not properly gel-coated. Marine-grade aluminum (5083 or 6061-T6) provides excellent corrosion resistance in saltwater, is fully recyclable, and allows welding repairs, but its higher density (~2.7 g/cm³) increases hull weight, requiring more power to achieve equivalent performance.
Industrial Applications
In environmental monitoring, electric jet boards enable quiet, zero-emission access to sensitive habitats such as mangrove forests, coral reef fringes, or nesting bird colonies where combustion engine noise and exhaust could alter wildlife behavior or contaminate samples. Their shallow draft allows deployment in intertidal zones during low tide to collect water quality samples, deploy sensors, or retrieve data loggers without grounding. Rescue operations benefit from rapid deployment—units can be launched from shore or small vessels in under 30 seconds—and the absence of exposed propellers reduces risk to swimmers or victims in the water during approach. Patrol agencies use them for harbor surveillance, smuggling interdiction, or monitoring marine protected areas, leveraging their low acoustic signature to avoid detection.
Aquaculture operators employ jet boards for net pen inspection, feed monitoring, and mort retrieval in salmon, tilapia, or shellfish farms, where traditional propellers risk damaging netting or entangling in mooring lines. The ability to operate at low speeds (<5 km/h) with precise throttle control allows station-keeping alongside pens without drift, improving operational safety and efficiency. In hydrographic surveying, jet boards serve as platforms for sidescan sonar, ADCP, or CTD sensors in shallow coastal surveys, rivers, or estuaries where larger vessels cannot navigate. Their electric drive eliminates magnetic interference that could distort compass readings or affect fluxgate magnetometers used in archaeological or UXO detection missions.
Industrial maintenance teams use jet boards for inspecting underwater infrastructure such as intake screens, dam faces, or bridge piers in freshwater reservoirs or rivers, where emissions restrictions prohibit combustion engines. The low wake generated minimizes turbidity, preserving visibility for visual inspections or optical sensor data. Construction support includes ferrying personnel or small tools to offshore wind turbine foundations during installation or maintenance, particularly in areas with restricted vessel access or strong tidal currents where precise maneuvering is essential. Film and media production crews utilize them for capturing water-level shots in protected areas where noise and emissions permits are difficult to obtain for conventional boats.
Customization and Integration Options
Propulsion power can be scaled by selecting different motor windings, inverter ratings, and battery configurations; a 7 kW system may suit recreational or light patrol use, while 12 kW+ variants are preferred for rescue or survey missions requiring higher speed or payload capacity. Nozzle diameter and impeller pitch are adjustable to shift the performance curve—larger nozzles increase mass flow at lower exit velocity, improving low-speed thrust and efficiency, while smaller nozzles favor high-speed operation. Steering mechanisms range from handlebar-linked nozzle vectoring (±20°) to rear rudder systems activated at speed, with some models offering electronic yaw control via differential thrust in dual-jet configurations.
Battery packs can be configured for hot-swapping, enabling continuous operation through rapid exchange—critical for surveillance or patrol missions where downtime must be minimized. Integrated payload mounts (MIL-STD-810 or NATO standard) allow attachment of sensors, communication devices, or small cargo (up to 15 kg) without compromising hull balance. Control interfaces include thumb throttles, twist grips, or foot-operated pedals, with optional GPS speed overlays, depth readouts, or collision avoidance alerts via CAN bus integration. For OEM integration, suppliers provide CAD models, electrical schematics, and communication protocols (CANopen, J1939, or NMEA 2000) to facilitate embedding the jet board into larger autonomous or remotely operated systems.
Cooling system design can be adapted to ambient conditions; in tropical climates, increased water flow through motor jackets or larger heat exchangers may be required to maintain safe operating temperatures, while in cold environments, battery pre-heating systems prevent lithium plating during charge. Hull color and surface finish can be customized for visibility (e.g., international orange for search and rescue) or low visibility (matte black or gray for tactical operations), with UV-stabilized gelcoats or polyurethane topcoats to resist chalking and degradation. Anti-fouling coatings (copper-free, silicone-based) are available for prolonged deployment in warm, nutrient-rich waters to inhibit biofilm growth that increases drag and accelerates corrosion.
Quality Control and Testing
Each unit undergoes hydrostatic pressure testing of the battery and electronics enclosures to verify IP67/IP68 compliance, typically involving submersion at 1 meter depth for 30 minutes followed by functional inspection. Motor insulation resistance is measured at 500 V DC, with acceptance criteria >100 MΩ to prevent leakage currents that could cause corrosion or electrical hazards. Thrust bench testing validates performance against specifications using a dynamometer to measure static thrust at varying voltages, ensuring the impeller-nozzle-motor system delivers expected force—e.g., a 10 kW system should produce approximately 180–220 N of thrust at peak power, depending on efficiency.
Functional testing includes acceleration runs (0–30 km/h time), top speed verification via GPS, and endurance testing at 75% continuous power for 30+ minutes to confirm thermal stability. Battery cycle life validation involves accelerated testing at elevated temperatures (e.g., 45°C) to predict real-world degradation, though actual performance depends on depth of discharge and charge rate. Non-destructive inspection (NDT) of hull laminates uses ultrasonic testing to detect delaminations, voids, or resin starvation, particularly in high-stress areas like the intake grate mounting and transom. Final inspection includes verification of all labels, warning decals, and user manuals—critical for liability reduction and regulatory compliance in commercial or governmental procurement.