Jet Powered Electric Surfboard
Jet-Powered Electric Surfboard: Technical Specifications and Industrial Applications
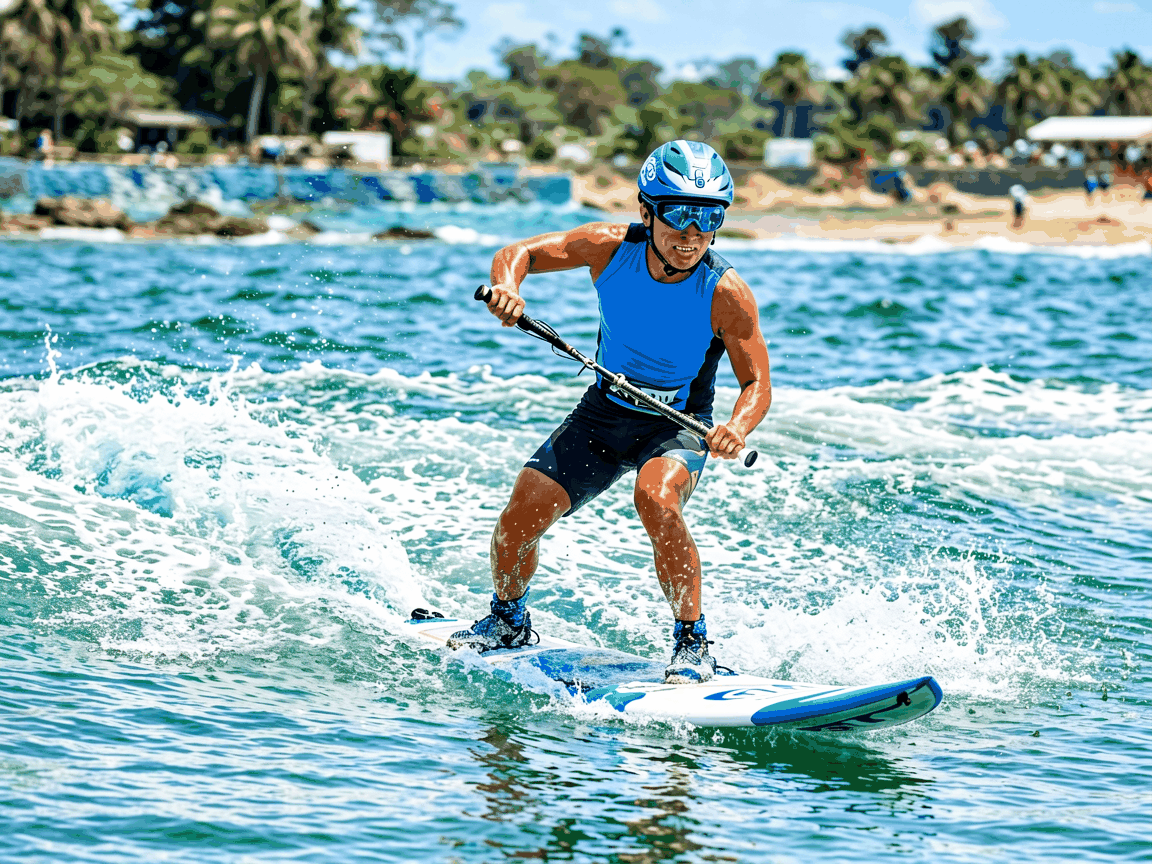
The jet-powered electric surfboard represents a specialized marine propulsion system designed for high-performance personal watercraft applications. Unlike conventional propeller-driven electric surfboards, this configuration utilizes a waterjet pump driven by a brushless DC motor to generate thrust through fluid acceleration. This design eliminates exposed rotating components, reducing entanglement risk and improving safety in shallow or debris-prone environments. The system integrates a sealed lithium-ion battery pack, electronic speed controller, and hydrodynamically optimized hull to deliver consistent thrust across varying water conditions.
Performance characteristics are defined by the interaction between motor power, pump efficiency, and hull resistance. Typical models deliver peak thrust between 800–1200 N, enabling planing speeds of 35–45 km/h depending on rider weight and water state. Battery capacity ranges from 2–5 kWh, providing operational endurance of 20–40 minutes at moderate throttle. Charging systems support Level 2 AC input (240V) with full recharge times of 2–3 hours. All electrical components are rated IP68 for continuous submersion, with corrosion-resistant materials used throughout the propulsion assembly.
Propulsion System Architecture
The core propulsion unit consists of a single-stage axial-flow waterjet pump coupled directly to an outrunner brushless motor. Motor stator windings are encapsulated in epoxy resin to prevent water ingress, while the rotor employs sintered neodymium magnets secured with carbon fiber retaining sleeves. Pump impeller and stator vanes are precision-machined from marine-grade stainless steel (AISI 316L) to resist cavitation erosion and electrochemical degradation. Flow straightening stators downstream of the impeller reduce swirl losses, improving propulsive efficiency by approximately 12–15% compared to unstraightened designs.
Thrust vectoring is achieved through a steerable nozzle mounted at the pump exit, actuated by a waterproof servo mechanism linked to handheld throttle/steering controls. Nozzle deflection angles typically range ±20°, enabling tight turning radii at speed. Reverse thrust capability is implemented via a deflector plate that redirects flow forward when activated, allowing for rapid deceleration and precise docking maneuvers. The entire propulsion module is mounted to the hull via vibration-isolating elastomeric brackets to minimize structural resonance and noise transmission.
Energy Storage and Power Management
Battery systems utilize lithium nickel manganese cobalt oxide (NMC) chemistry arranged in modular packs with integrated battery management systems (BMS). Each module includes cell balancing, temperature monitoring, overcurrent protection, and isolation fault detection. Pack enclosures are constructed from extruded aluminum with internal cooling channels to maintain optimal cell temperatures during discharge. Nominal voltage ranges from 48–72 VDC depending on configuration, with maximum continuous current ratings between 100–200 A.
Power delivery is managed by a field-oriented control (FOC) algorithm in the electronic speed controller (ESC), which adjusts motor torque based on throttle input while monitoring motor temperature, battery state-of-charge, and system faults. Regenerative braking is not typically implemented due to low energy recovery potential during deceleration in planing hulls, though some prototypes incorporate limited regen during nozzle reverse thrust activation. Thermal throttling protects electronics during extended high-load operation, reducing power output by 10–20% when internal temperatures exceed 85°C.
Charging interfaces use waterproof connectors rated for 500+ mating cycles, supporting both AC charging via onboard converter and DC fast charging (where available). State-of-charge estimation employs coulomb counting adjusted by voltage relaxation models, with accuracy within ±3% under stable conditions. Emergency shutdown is triggered by dual redundant systems: hardware overcurrent cutoff and software-based fault detection from the ESC.
Hull Design and Hydrodynamics
Hull geometry is optimized for minimal drag at planing speeds while maintaining stability during low-speed maneuvering. Primary construction materials include carbon fiber-reinforced polymer (CFRP) skins over a closed-cell PVC foam core, providing a strength-to-weight ratio suitable for impact resistance and stiffness requirements. Alternative constructions use fiberglass or thermoplastic composites for cost-sensitive applications, though with increased weight and reduced fatigue life. Hull volume is carefully calculated to ensure adequate buoyancy with safety margins for rider weight, equipment, and dynamic wave effects.
Bottom contours feature a combination of concave sections for lift generation and stepped edges to reduce wetted surface area. Rocker profile (longitudinal curvature) is tuned to prevent pitch instability at high speeds while allowing easy takeoff from flat water. Sidewalls incorporate flared sections to enhance spray resistance and improve stability in choppy conditions. All external surfaces are coated with a UV-stable polyurethane finish to prevent degradation from prolonged sun exposure and saltwater immersion.
Footstrap and handle placements are ergonomically positioned based on anthropometric data to optimize rider control and weight distribution. Deck inserts are molded during layup to avoid post-drilling weak points, with reinforcement patches applied at high-load locations. Drainage scuppers are integrated into the transom to allow water ejection when stationary, preventing accumulation that could affect trim and handling.
Typical Performance Parameters
| Parameter | Typical Range | Notes |
|---|---|---|
| Peak Thrust | 800–1200 N | At full throttle, varies with pump diameter and motor KV |
| Planing Speed | 35–45 km/h | Dependent on rider weight (70–100 kg) and water conditions |
| Battery Capacity | 2–5 kWh | NMC chemistry, 48–72 VDC nominal |
| Endurance | 20–40 minutes | At mixed throttle, 25°C ambient water |
| Charge Time (AC) | 2–3 hours | Level 2, 240V input, onboard charger |
| Operating Temperature | 0–40°C ambient | Battery performance derates outside this range |
| IP Rating | IP68 (static submersion) | All electrical enclosures, connectors, and sensors |
Industrial and Professional Applications
Beyond recreational use, jet-powered electric surfboards serve specific professional maritime operations where low noise, zero emissions, and shallow-water capability are critical. In coastal environmental monitoring, these platforms enable quiet approach to sensitive habitats for wildlife observation or water sampling without disturbing ecosystems or relying on fossil fuel-powered vessels. Their maneuverability allows operation in confined areas such as mangrove channels or coral reef zones where traditional boats risk grounding or ecological damage.
In lifeguard and rescue operations, the rapid deployment and high acceleration provide advantages over swimmer-based approaches in near-shore incidents. The absence of exposed propellers reduces injury risk to both rescuers and victims during close-proximity assistance. Some models are configured with tow points and flotation aids to support conscious or unconscious individuals back to shore. Battery endurance supports multiple rescue attempts on a single charge, with quick-swap systems under evaluation for extended missions.
Marine research institutions utilize these boards as sensor platforms for collecting bathymetric, thermal, or chemical data in littoral zones. Their small wake minimizes disturbance to measurement instruments, and electric propulsion eliminates fuel contamination risks in water samples. Custom mounting points allow installation of sonar, CTD probes, or underwater cameras. Data logging systems are often integrated with the board’s CAN bus to synchronize sensor readings with GPS position and speed.
Customization and Integration Options
Manufacturers offer scalable propulsion modules ranging from 5–15 kW peak power to accommodate different hull sizes and performance requirements. Motor winding configurations can be adjusted for torque-speed tradeoffs, with higher pole counts favoring low-speed thrust and lower counts enabling higher top speeds. Pump impeller diameter and blade geometry are selectable based on target thrust density and cavitation limits. Shaft seals and bearing types are available in ceramic or silicon carbide variants for abrasive environments.
Battery packs support series-parallel reconfiguration to meet specific voltage and capacity needs, with options for heated or cooled enclosures in extreme climates. Communication interfaces include CANopen, UART, and analog inputs for integration with external control systems or telemetry units. Control handles can be customized with alternative grip styles, thumb throttle orientations, or secondary function buttons for auxiliary equipment activation.
Hull customization extends to length, width, rocker profile, and attachment points for mission-specific gear. Color options are available through gelcoat or paint systems, with non-slip deck textures selectable by grit level and material. For OEM integrations, manufacturers provide ICDs (Interface Control Documents) detailing mechanical mounting points, electrical connectors, and communication protocols to facilitate third-party system integration.